Smooth like honey.
HD 01
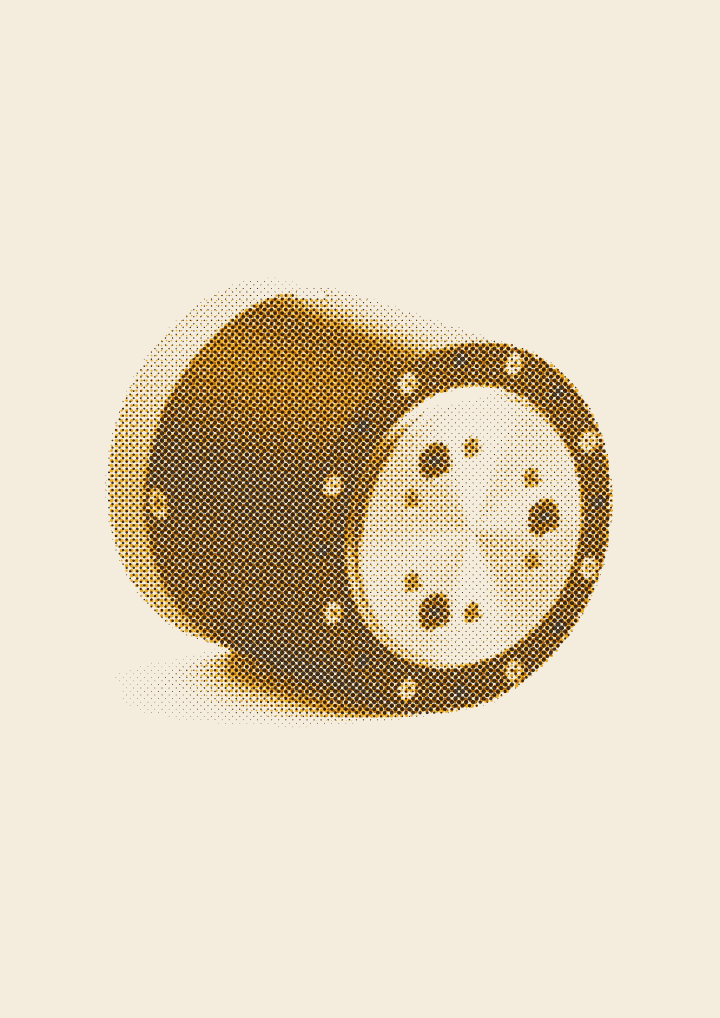
The HD 01 is a compact, backdrivable smart actuator for the mid-range joint.
Most joints in a robot or an automated machine fall between 5 and 30 Nm. The HD 01 is designed to support the mid-range.
Designed for domestic-content requirements.
14–16 Nm peak 4 Nm continuous 24 V CAN FD Backdrivable
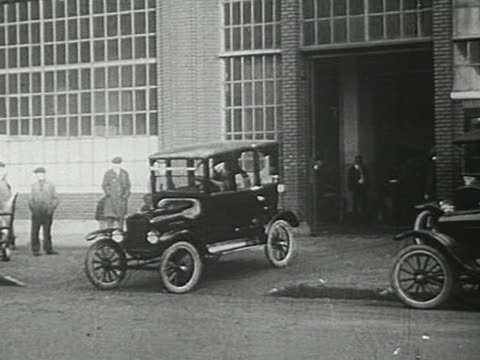
Model Ts roll out under the Highland Park plant.
Applications
Robotics
- Humanoids
- Quadrupeds
- Research platforms
- Robot arms
Industrial automation
- Light cobots
- Carts
- Gimbals
Medical devices
- Exoskeletons
- Rehabilitation
Logistics
- Carts
- Picking arms
Government projects
- Ground robotics
- Field equipment
Entertainment
- Animatronics
The craft
Control
Motor-drive engineers designed the controller and firmware in-house. The board runs torque control from 12 to 48 V.
Motion
We match the gear ratio to the motor and choose gearing with low backlash. The HD 01 moves smoothly under load and turns freely by hand with the power off.
Measurement
Every HD 01 ships with full documentation and torque curves measured on our own bench.
The assembly
One housing, about 50 mm across, holds the motor, gearing, encoder and controller. There is nothing to add before it joins your machine.
It mounts and talks like the class standard, so it drops into an existing joint without adapter work. Command it over CAN FD from any controller between 12 and 48 V, 24 V nominal. It backdrives smoothly when you turn it by hand, and every unit ships with its measured torque curve.
24 V nominal 12 to 48 V CAN FD 50 mm across backdrivable
Specifications
| Parameter | Value |
|---|---|
| Peak torque | 14 to 16 Nm |
| Continuous torque | 4 Nm |
| Reduction | Low-backlash gearing |
| Supply voltage | 24 V nominal; the controller accepts 12 to 48 V |
| Communication | CAN FD, 5 Mbps |
| Backdrivable | Yes |
| Construction | Motor, gearing, encoder and controller in one housing |
| Size | About 50 mm across |
Design figures. Testing not complete.
Honeydrive started when we needed the best mid-range actuators for our robots and could not get them in the United States. We spun the company out of YES! Inc. to build them here.
Our mission is preventing deceleration in robotics, domestic and global, by building its motion infrastructure in America. We do it by bringing the work of masters of craft back to American manufacturing.
The team behind it has designed motor drives and power electronics for electric vehicles, written motion-control software used on automotive production lines, built its own circuit-board assembly lines, spent years building national-security hardware at a federal laboratory, and engineered a 20-joint walking robot.
Join the waitlist
Tell us who you are and how many units you need.